Whole-body grasp generation
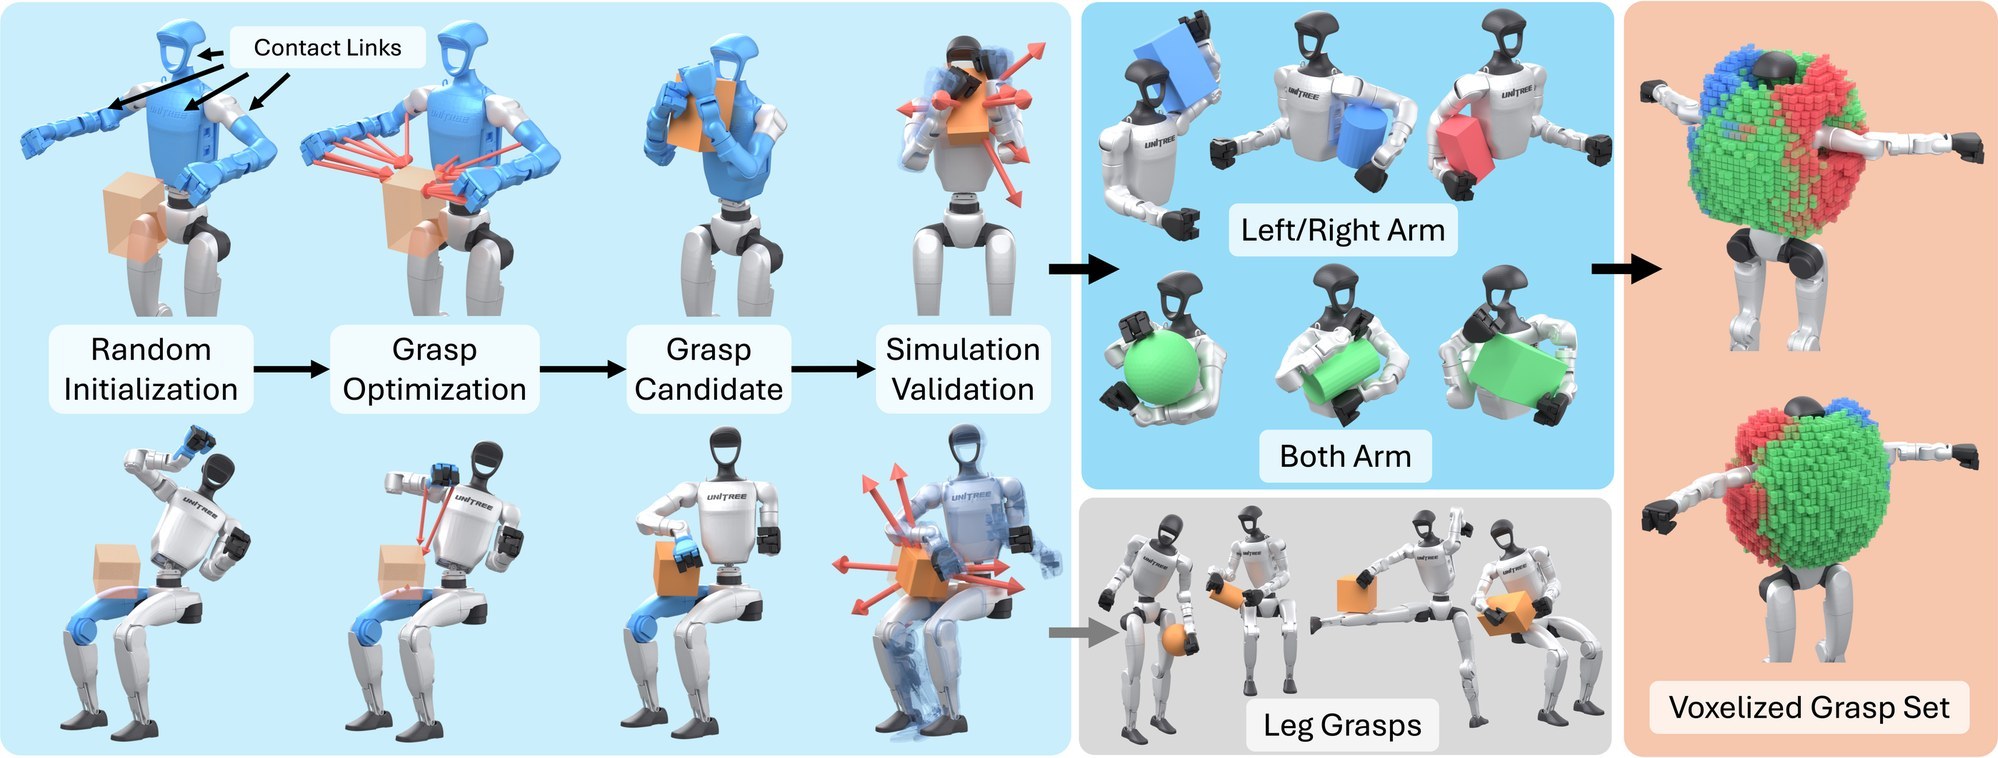
Energy-based optimization and simulation filtering produce the arm-and-torso grasp cache used for training.
Try out interactive whole-body dexterous experts!
Try out the general WBD Controller with body pose tracked teleoperation! It will refine your teleoperation inputs into safe and stable object repositioing and avoid unstable actions!
Try the general distilled WBD policy interactively on a desktop computer.
Energy-based optimization and simulation filtering produce the arm-and-torso grasp cache used for training.
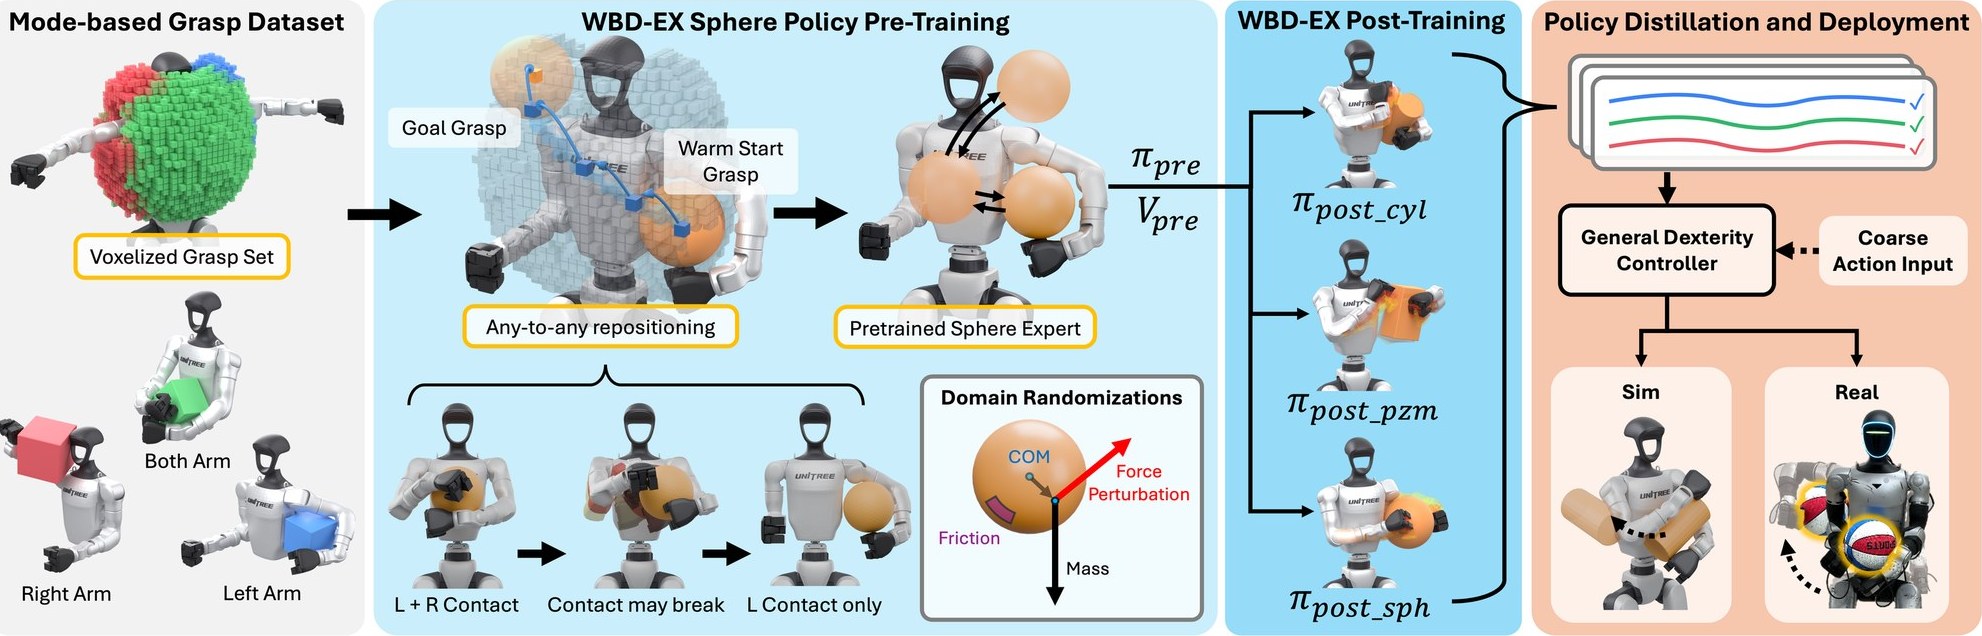
Reinforcement-learning experts learn to reposition an object and settle it in a left-arm, both-arm or right-arm hold, using goals sampled from the grasp cache.
The experts are distilled into one deployable policy that transfers zero-shot to a real Unitree G1 and is steered interactively by a teleoperator.
Generate whole-body grasps, train experts to move objects between them, then distill the experts into one controller.
Grasps are optimized from chosen contact links (blue), then kept only if they survive perturbations in simulation.
Experts start from cached grasps and learn to move objects toward sampled positions in left-arm, both-arm or right-arm holds. Intermediate goals connect the current position to a farther goal, allowing sliding and rolling across the torso.
We add noise to expert commands and compare direct execution with WBD refinement. The guidance weight controls how strongly motion generation follows the coarse command.
Completed trials across two on-body repositioning tasks with a basketball and a cardboard box, plus a shelf-to-table task. GMR (General Motion Retargeting) directly retargets the operator’s motion; SONIC is a generalist whole-body controller.
In the real-world experiments, an Xsens motion capture suit provides coarse motion references. WBD refines the arm targets; a separate controller handles lower-body motion and balance.
Shoulder tap requires object contact with the shoulder. Underarm stow requires the object center to reach shoulder depth in a stable single-arm hold. A full round trip returns to a stable two-arm front grasp.
SONIC
GMR
WBD (ours)
Shoulder tap
Underarm stow
| Task | Controller | Region reached ↑ | Full round trip ↑ | Time to region (s) ↓ | Total time (s) ↓ |
|---|---|---|---|---|---|
| Shoulder tap | SONIC | 2/10 | 0/10 | 15.2 | — |
| GMR | 3/10 | 1/10 | 26.0 | 30.1 | |
| WBD | 10/10 | 9/10 | 7.7 | 17.3 | |
| Underarm stow | SONIC | 1/10 | 0/10 | 28.0 | — |
| GMR | 4/10 | 2/10 | 31.5 | 49.8 | |
| WBD | 10/10 | 9/10 | 10.6 | 26.2 |
| Task | Controller | Region reached ↑ | Full round trip ↑ | Time to region (s) ↓ | Total time (s) ↓ |
|---|---|---|---|---|---|
| Shoulder tap | SONIC | 2/10 | 2/10 | 15.9 | 24.9 |
| GMR | 6/10 | 4/10 | 8.0 | 8.5 | |
| WBD | 10/10 | 10/10 | 4.1 | 6.3 | |
| Underarm stow | SONIC | 2/10 | 0/10 | 26.1 | — |
| GMR | 2/10 | 1/10 | 9.3 | 17.8 | |
| WBD | 10/10 | 10/10 | 8.6 | 13.0 |
Ten trials per controller, object and task, five per side. Times are measured from trial start and averaged over trials reaching the respective endpoint.
| Controller | Pick ↑ | Stow ↑ | Carry ↑ | Un-stow ↑ | Place ↑ |
|---|---|---|---|---|---|
| SONIC | 10/10 | 0/10 | 0/10 | 0/10 | 0/10 |
| GMR | 10/10 | 3/10 | 2/10 | 1/10 | 1/10 |
| WBD | 10/10 | 9/10 | 9/10 | 9/10 | 7/10 |
@misc{mcgartoll2026wholebody,
  title  = {Whole-Body Dexterity},
  author = {Conor Mc Gartoll and An Dang and Pranay Thangeda
            and Arjun Gupta and Carolina Higuera and Nima Fazeli
            and Mustafa Mukadam and Manikantan Nambi},
  year   = {2026},
  url    = {https://wholebodydexterity.com}
}